

We're building real-world foundational models for physical AI, so people and machines can work efficiently and safely together.
Earth
- Tweets 6,041
- Following 85
- Followers 957,633
- Likes 4,206



Fly through the world in 3D 🌎
Captured by iROBOTICS, Inc. with a DJI Osmo 360 and reconstructed in Scaniverse, this Gaussian splat of Kutani Dam shows the potential of large-scale 3D reconstruction for infrastructure planning and assessment.
Start today with Scaniverse. hubs.ly/Q04z2-df0
#WorldModels #RealWorldModels #SpatialAI #PhysicalAI #AI #GaussianSplat #RealityCapture #3DGS #3DReconstruction

3
14
84
30,422
Niantic Spatial 🌎 retweeted

The Antigravity A1 360 drone, Niantic Spatial’s Scaniverse, and Apple Vision Pro are such an awesome combo for creating and experiencing Gaussian splats.
This one has more than 5 million splats. Still kind of blows my mind.

4
16
131
9,291
Headed to #AES2026 in Atlanta?
Join us for the opening keynote, “Let’s Get Physical: Enterprise AI in the Real World,” featuring Niantic Spatial CEO Inhi Cho Suh.
Explore our full AES activation, including an exclusive demo party co-hosted by Spexi: hubs.ly/Q04yGsrY0
#PhysicalAI #SpatialAI #AI

9
14,569
Niantic Spatial 🌎 retweeted

reality. computable.
a short film i built inside a high-fidelity real-world gaussian splat with astra in a couple hours, showcasing the work we're doing @nianticspatial to make the physical world computable for machines.
🌍: leake street arches, london.

4
6
48
18,257
Join Niantic Spatial and @RLWRLD_ai during SF Tech Week for Physical AI in the Real World.
See live demos of five-finger dexterous robotic manipulation + real-world understanding.
Oct 7 | 2:30–5:30 PM PT
Space is limited! RSVP here: hubs.ly/Q04ywDKV0
#EmbodiedAI #PhysicalAI #AI #Robotics #SFTechWeek

13
14,955
Introducing the Places Library 📚
A collection of 100 high-fidelity, real-world 3D environments built for embodied AI.
Instantly access real-world 3D environments as simulation-ready USDZ files, ready to use in NVIDIA Isaac Sim, Isaac Lab, and compatible OpenUSD simulators.
🔗 Read more: nianticspatial.com/blog/intr…
👉 Download free sample scenes: nianticspatial.com/embodied-…
#EmbodiedAI #Robotics #PhysicalAI #Real2Sim #IsaacSim #AI #USDZ

6
21
188
48,209
Niantic Spatial 🌎 retweeted
today at @nianticspatial we're launching the Places Library: 100 real environments to train robots in, with even more coming soon.
warehouse, last mile, residential, and more. every one a simulation-ready USDZ. start here, then capture the sites you actually deploy into.

32
67
552
76,667
Big news: @DaveCitron joins Niantic Spatial as Chief Product Officer.
After leading products at @MicrosoftAI and @GoogleDeepMind, Dave joins us to build the spatial layer for physical AI, giving machines the intelligence to reason, learn and act in the physical world.
Welcome to the team, Dave.
Read more: hubs.ly/Q04ybP_l0
#PhysicalAI #SpatialAI #AI #Leadership #NianticSpatial

2
1
29
16,312
Some places are worth preserving in every dimension.
Captured by Razvan Onisca and reconstructed with Scaniverse, Detunata Goală shows how 3D reconstruction can preserve natural environments, detect change, support hazard awareness, and enable navigation where GPS falls short.
Learn more: hubs.ly/Q04ybPbL0
#PhysicalAI #SpatialAI #3DReconstruction #GaussianSplat #RealityCapture #Scaniverse #AI #3DGS

2
3
32
20,829
The real world is the ultimate test. Move from pilot to production faster.
Turn real deployment sites into simulation-ready digital twins. Train and evaluate robot policies against real-world geometry and conditions before deployment.
We’re looking for a small group of design partners to help shape what comes next, from generative variation to a continuous loop between deployment and simulation.
👉 Learn more: hubs.ly/Q04y8hc80

2
5
18
22,380
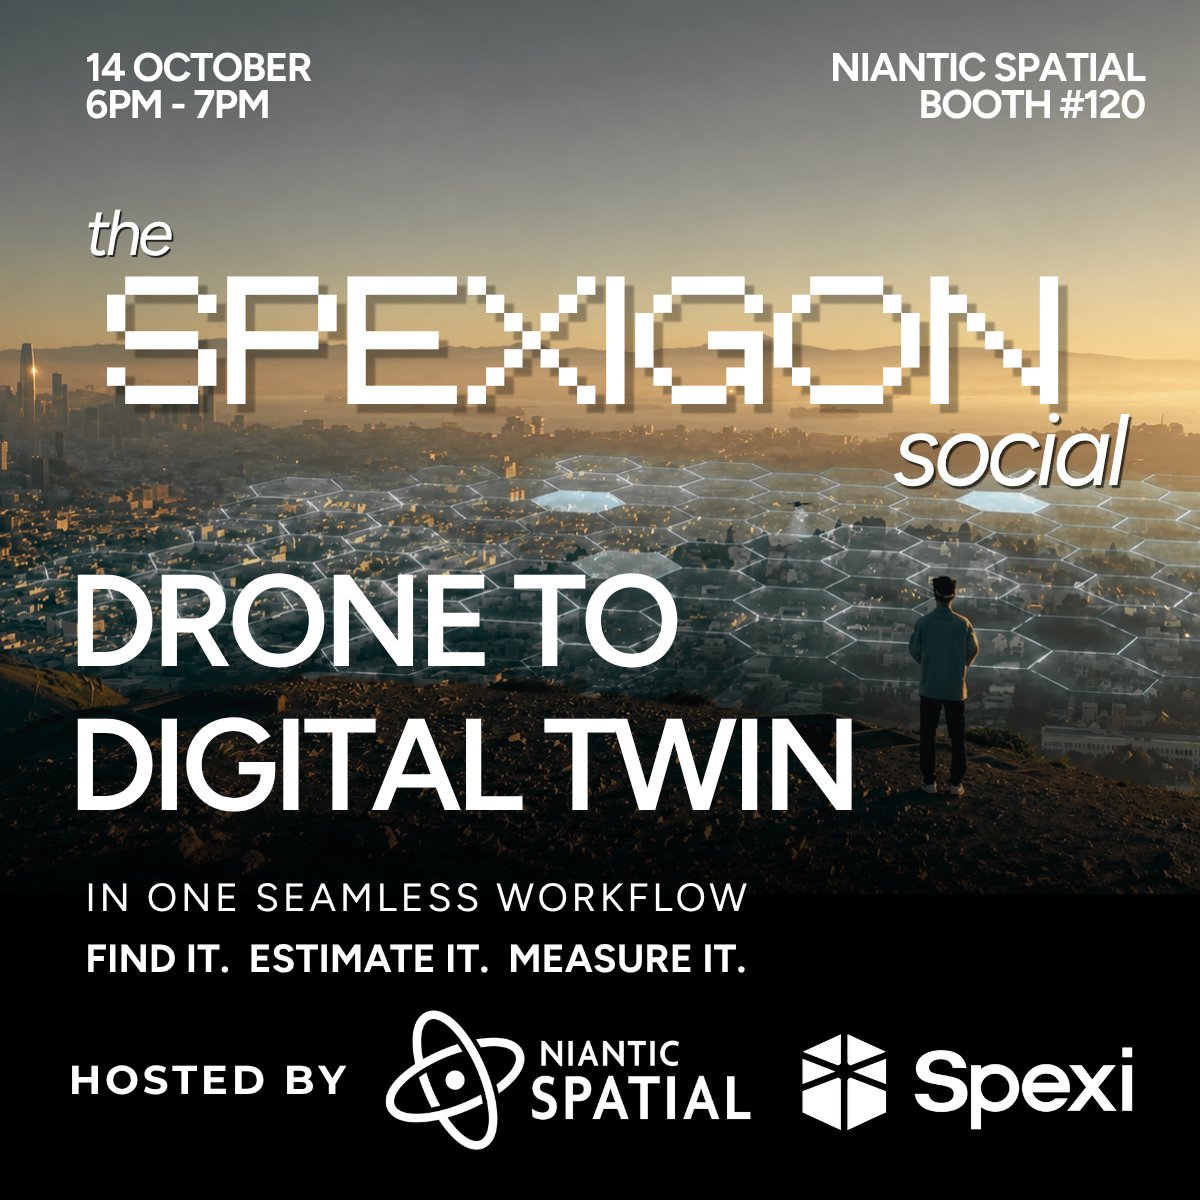
Heading to #AES2026?
Join Niantic Spatial & @SpexiGeospatial for a Demo Party with drinks, live demos, and a look at drone-to-3D in action.
See how aerial capture becomes an actionable, measurable 3D representation of the real world, meet the teams, and enter for a chance to win a DJI Mini 3 drone!
RSVP here: hubs.ly/Q04y3SBB0
#AES2026 #NianticSpatial #Spexi #SpatialAI #3DGS #RealityCapture #Drones #GaussianSplat #AI #PhysicalAI
3
17
17,257
The future of Physical AI is city-scale.
Together, Niantic Spatial and Singapore Land Authority (SLA) are exploring what it takes to enable precise, city-scale Physical AI.
👉 Read more: hubs.ly/Q04xWlJP0
▶️ Learn more about SLA: hubs.ly/Q04xWlFt0
#PhysicalAI #SpatialAI #Robotics #SmartCities #AI

7
32
23,291
@KitGilbert is now GM of our new Embodied AI business, leading Niantic Spatial's work on building the scalable real-to-sim stack where embodied AI learns visual-spatial intelligence.
Building for Embodied AI? Talk to Kit and learn more here: hubs.ly/Q04xVp-C0
#PhysicalAI #Real2Sim #EmbodiedAI #Robotics

11
16,202
☀️🌧️ Introducing Gaussian Splat Relighting, now in beta.
Train embodied AI for changing real-world conditions.
Using aligned meshes, we simulate new illumination and transfer it onto Gaussian splats—generating lighting, weather + time-of-day variants while preserving the underlying geometry, navigation + semantic data.
Read more: hubs.ly/Q04xQyZM0
#GaussianSplats #EmbodiedAI #PhysicalAI #Real2Sim #3DGS #Robotics #ComputerVision #A

7
42
209
31,616
Robots will operate in the physical world. The closer the simulation is to reality, the better robots can prepare for it.
At @HumanoidsSummit Seoul, CEO @InhiChoSuh will share how Niantic Spatial’s real-world foundation models bridge the Real2Sim gap to enable faster, safer, more reliable robot deployment.
Explore our Real2Sim2Real workflows and policy training with Flexion and NVIDIA:
nianticspatial.com/blog/flex…
#PhysicalAI #Robotics #SpatialAI #AI

Meet Inhi Cho Suh, CEO of @NianticSpatial, at the Humanoids Summit Seoul.
Join the conversation and network with the leaders shaping the future of Physical AI.
Grab your ticket and be part of the conversation: humanoidssummit.com
#HumanoidsSummit #Seoul #Robotics #PhysicalAI

6
13
26,799
World models that aren't grounded in the real world will never reach their potential for physical AI. 🌎
Just as RAG cut hallucination in LLMs, location-specific grounding lets robots choose the right action in the right place.
Read more about Niantic Spatial’s thinking: hubs.ly/Q04xBplB0
#WorldModels #PhysicalAI #AI #EmbodiedAI #SpatialAI #Robotics
3
11
44
34,722
🤖 What will it take to scale Physical AI?
Niantic Spatial CEO @InhiChoSuh joins industry leaders at AI Infrastructure Summit in Santa Clara to discuss where today’s Physical AI architectures work, where they break, and what it will take to reach the next breakthrough.
📅 September 16 | 2:20 PM
👉 Learn more hubs.ly/Q04xgWKf0
#PhysicalAI #Robotics #SpatialAI #EmbodiedAI #AI

1
7
17,713
Tomorrow at @eccvconf 2026, we’re presenting AutoCompass.
Given a photo + a 2D public map, AutoCompass can determine where the camera is and which way it’s facing, even when training data has noisy GPS and no heading labels.
The result: precise localization anywhere a public map exists.
Paper: arxiv.org/abs/2609.02798
Website: nianticspatial.github.io/aut…
Video: piped.video/watch?v=hmUF6p3C…
#ECCV2026 #PhysicalAI #SpatialAI #ComputerVision #AI

2
12
38
21,454