

MS @IllinoisCS
- Tweets 40
- Following 1,315
- Followers 97
- Likes 202
Henry Che retweeted

We'll present Déjà View as Oral at #NeurIPS 🎉
TL;DR: we beat VGGT-Ω on average with a 10x smaller, looped architecture.
Check it out 👇

Do 3D reconstruction transformers really need a billion parameters, or are most of those layers just doing the same thing over and over?
Introducing Déjà View: a single transformer block, looped K times, that matches or beats models 8–10× its size with lower compute. 🧵

8
17
211
17,188


Henry Che retweeted

Introducing OM-1, our first robot foundation model, zero-shot generalizing to any robot: table-top arms, industrial arms and humanoids.
- learned directly from human manipulation data
- no teleop/robot data
- close to human-level dexterity and efficiency
- multi-robot collab

154
480
3,507
1,758,681
Henry Che retweeted

Super excited to introduce Fire3D, which turns an unsegmented image or casual RGB video into a complete, textured, simulation-ready 3D scene in under a minute.
No supplied object poses or segmentations.
Project Page: xiahongchi.github.io/Fire3D/

7
36
371
17,728

The Waabi team is headed to Vienna for ICRA, the International Conference on Robotics and Automation 2026, June 1–5!
We're presenting four research papers and celebrating a major milestone — our very own @JurvandenBerg will be honored with the @IEEEorg Most Influential Paper Award.
Come find us and explore the future of Physical AI and autonomous driving: waabi.ai/icra-2026


3
8
1,568
Henry Che retweeted

The latent-vs-pixel debate misses the point.
GPT Image 2 shows what users notice: pixel-level fidelity.
Latent models show what scales: compact semantic structure.
We connect them by replacing VAE/RAE decoders with a Pixel Diffusion Decoder.
Code and Model available: research.nvidia.com/labs/sil…
🧵(1/N)

16
62
406
669,675
Henry Che retweeted

Awesome. NVIDIA dropped PiD - fast high-res latent decoding via pixel diffusion!
- replace VAE
- 4/8x upsampling
- 2k decoding in <1s on RTX 5090
- works with FLUX.1/SD3/Z
- rapid generation previews
sharper details, much lower hardware lag compared to standard methods.
research.nvidia.com/labs/sil…


7
61
425
23,801
Henry Che retweeted
We scaled up Lyra to generate explorable 3D worlds! 🚀
Introducing Lyra 2.0 — turning a single image into a 3D world you can walk through, look back, and even drop a robot into 🤖
Code and Model available today!
🌐 Website: research.nvidia.com/labs/sil…
(1/N)

27
115
855
1,148,228
Henry Che retweeted

At #GTC26 we are showing AlpaDreams — generative, interactive closed-loop simulation for autonomous driving.
World models generate environments in real time, policies or drivers interact, and the simulator updates the world.
If you are at GTC, come by the booth and try it out!

2
18
61
16,999
Henry Che retweeted

This week at @NVIDIAGTC we're presenting AlpaDreams: a generative world model for driving simulation. Compared to standard video models, AlpaDreams is autoregressive, enabling updating the conditioning (simple bounding box world) in closed loop, and multiview-consistent.

2
21
74
6,086
Henry Che retweeted

A new generation in AV simulation is here!
We are announcing AlpaDreams, a real time interactive generative world model for AV simualtion! Just a year ago it took minutes to generate a few seconds of video, today it is real time and interactive!
research.nvidia.com/labs/sil…
5
26
105
19,032
Henry Che retweeted
Here we introduce SAGE: Scalable Agentic 3D Scene Generation for Embodied AI, which can generate sim-ready 3D scenes with agents following user demands at scale, ready for robotic action generation. Paper, code, and SAGE-10k dataset are all released!
nvlabs.github.io/sage/

4
43
316
28,620
Henry Che retweeted
Awesome to see @Waymo launching a new model! 🎉
We worked on a similar demo over a year ago — the code and checkpoints are already open-sourced here:
🔗 research.nvidia.com/labs/tor…
Love seeing continued momentum in autonomous driving research 🚗✨

We’re excited to introduce the Waymo World Model—a frontier generative mode for large-scale, hyper-realistic autonomous driving simulation built on @GoogleDeepMind’s Genie 3.
By simulating the “impossible”, we proactively prepare the Waymo Driver for some of the most rare and complex scenarios—from tornadoes to planes landing on freeways—long before it encounters them in the real world.
waymo.com/blog/2026/02/the-w…
3
4
26
4,227
We are building a brain to power the entire Physical AI ecosystem.
Our Physical AI Platform combines a verifiable end-to-end AI model capable of reasoning with the world's most advanced neural simulator. For the first time in the industry, one AI brain powers multiple applications—trucks and robotaxis—where progress in one directly improves the other.
Proven in autonomous trucking. Now expanding to robotaxis. Built to scale across form factors, geographies, and environments.
Learn more: waabi.ai/insights/waabi-secu…

3
16
141
5,649
Henry Che retweeted

Physical AI's moment is here, and self-driving is the first manifestation of Physical AI that will scale.
We have built a Physical AI Platform that enables true scale and generalizes across form factors, geographies, and environments. It is proven in autonomous trucking and we are now expanding to robotaxis.
Our Platform combines a verifiable end-to-end AI model capable of reasoning with the world's most advanced neural simulator—powering the @Waabi_ai Driver. This approach enables, for the first time in the industry, a shared brain across both applications, meaning the same AI model will drive both trucks and robotaxis. This is important as any progress will directly benefit both verticals.
Furthermore, our capabilities already cover highways and surface streets, which has enabled our Direct to Customer model in trucking, providing a big product advantage with the rest of the industry. This also means that we have already all the core capabilities needed for robotaxis, allowing us to enter very fast and seamlessly this new market.
To achieve this, we have raised $1B USD of new capital, the largest fundraise in Canadian history. This capital will be used to accelerate commercial progress in autonomous trucks and to fuel our expansion into robotaxis. This funding includes an oversubscribed $750M Series C led by @khoslaventures Ventures and @G2VPLLC , as well as additional capital from @Uber tied to robotaxi development.
We are thrilled to work with Uber to deploy robotaxis powered by the Waabi Driver on the Uber platform, the largest ridesharing network globally. Through this strategic partnership, we will deploy 25,000 or more Waabi Driver-powered robotaxis, substantially accelerating the adoption of robotaxis at scale.
I am incredibly grateful to our team for making this vision a reality, to our investors, partners and customers for believing in what we are building together.
Read more: waabi.ai/insights/waabi-secu…

8
10
72
8,196
We have built a Physical AI Platform that enables true scale and generalizes across form factors, geographies, and environments. It is proven in autonomous trucking and we are now expanding to robotaxis.
Learn about what we are building: waabi.ai/insights/waabi-secu…
2
1
26
2,227
Today, we are thrilled to announce that we have raised $1B USD of new capital to accelerate commercial progress in autonomous trucks and expand to robotaxis!
For the first time in the industry, this enables one shared brain to power both applications—trucks and robotaxis. This means any progress in one vertical directly improves the other.
This funding includes an oversubscribed $750M Series C round led by @khoslaventures and @G2VPLLC, as well as additional capital from @Uber tied to robotaxi development. We are excited to work with Uber to deploy 25,000 or more Waabi Driver-powered robotaxis on the Uber platform, substantially accelerating the adoption of robotaxis at scale.
Thank you to our incredible team, investors, partners, and customers for helping us achieve this milestone. Here's to pioneering the future of Physical AI, together.

19
44
328
165,345
Henry Che retweeted

Bring new robot testing environments to life with @theworldlabs and Isaac Sim. 🤖 If you can describe a world 🌎, you can start testing in it the same day.
Learn how to:
1. Export scenes from World Labs' Marble as Gaussian splats
2. Convert to USD using @nvidiaomniverse NuRec
3. Import into NVIDIA Isaac Sim
4. Add a robot and run the simulation
Read the guide ➡️ nvda.ws/3N4Yf5K
#SIGGRAPHAsia2025

14
107
654
158,820
Henry Che retweeted

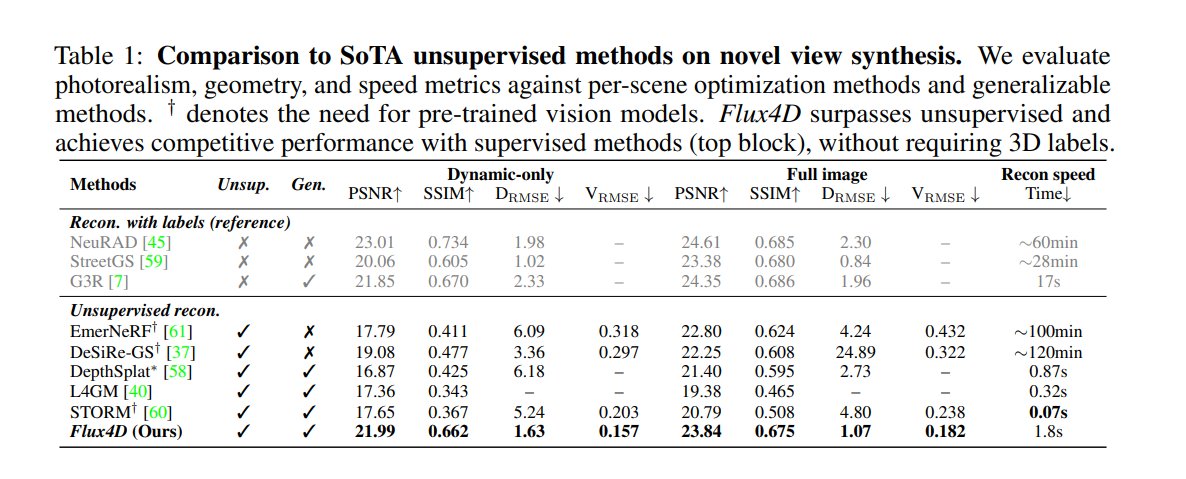
Flux4D: Flow-based Unsupervised 4D Reconstruction
Abstract (excerpt):
Flux4D is a simple and scalable framework for 4D reconstruction of large-scale dynamic scenes. It directly predicts 3D Gaussians and their motion dynamics to reconstruct sensor observations in a fully unsupervised manner.
By adopting only photometric losses and enforcing an "as static as possible" regularization, Flux4D learns to decompose dynamic elements directly from raw data without requiring pre-trained supervised models or foundational priors. This is achieved simply by training across many scenes.
Our approach enables efficient reconstruction of dynamic scenes within seconds, scales effectively to large datasets, and generalizes well to unseen environments, including rare and unknown objects.
Experiments on outdoor driving datasets show that Flux4D significantly outperforms existing methods in scalability, generalization, and reconstruction quality.

2
14
109
5,260
Henry Che retweeted

Flux4D: Flow-based Unsupervised 4D Reconstruction
@wangjksjtu, @hungdche, @ycchen918, @yangze0930, @lily_goli, Sivabalan Manivasagam, @RaquelUrtasun
tl;dr: photometric losses and simple static-preference prior
arxiv.org/abs/2512.03210



1
9
58
3,340